General-purpose agents
I study how to train agents to search, use tools, and reason through multi-step tasks, using reinforcement learning and feedback from interactions.
Selected work: ZeroSearch
Reasoning · Tool Use · LearningJiayan Guo
Tencent · General-purpose agents
Model post-training
Three papers accepted at NeurIPS 2026.
I study how to train agents to search, use tools, and reason through multi-step tasks, using reinforcement learning and feedback from interactions.
Selected work: ZeroSearch
Reasoning · Tool Use · LearningMy work on embodied intelligence covers perception, spatial reasoning, vision-language-action models, and world models.
Selected work: RynnBrain · WorldVLA · RynnVLA-001 / 002
Perception · Reasoning · ActionPHYSICAL INTELLIGENCE · EMBODIED FOUNDATION MODELS
One of the project leads
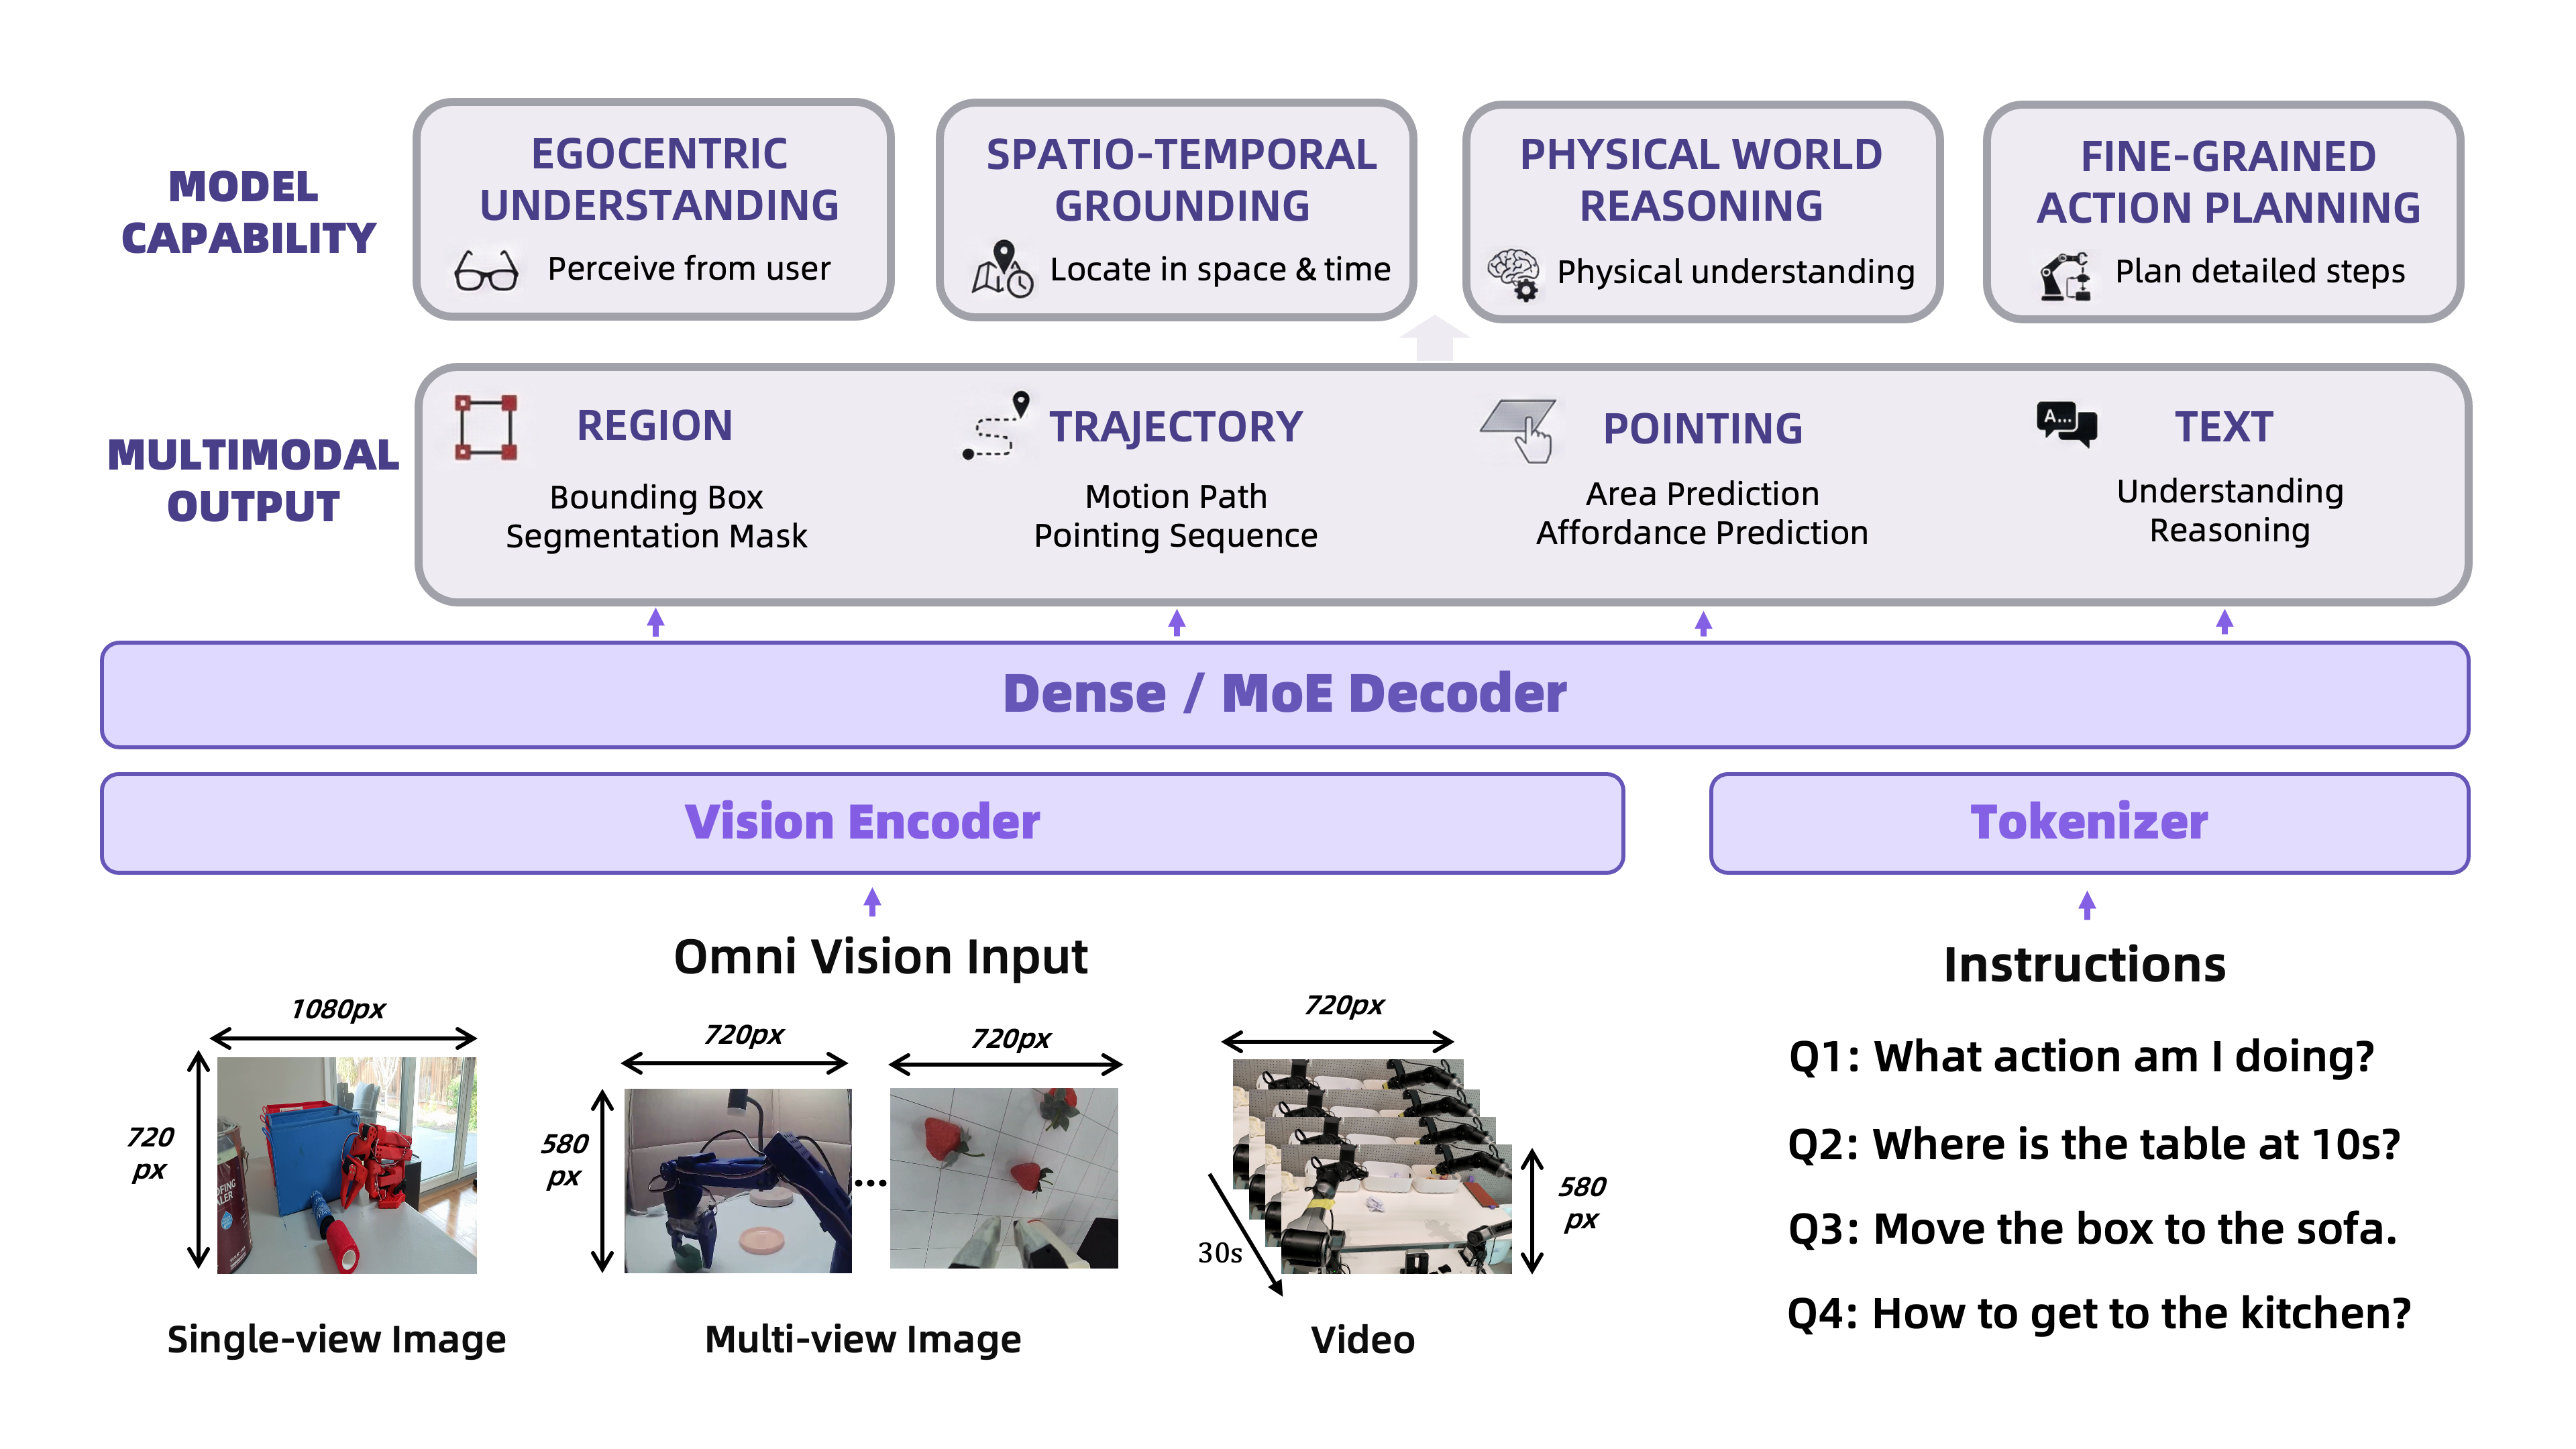
An open-source embodied foundation model for egocentric perception, spatiotemporal grounding, physical reasoning, and planning. Contributions include pre-training, Chain-of-Point reasoning, VLA, and training infrastructure.
GENERALIST AGENTS · SEARCH & TOOL USE
Co-corresponding author
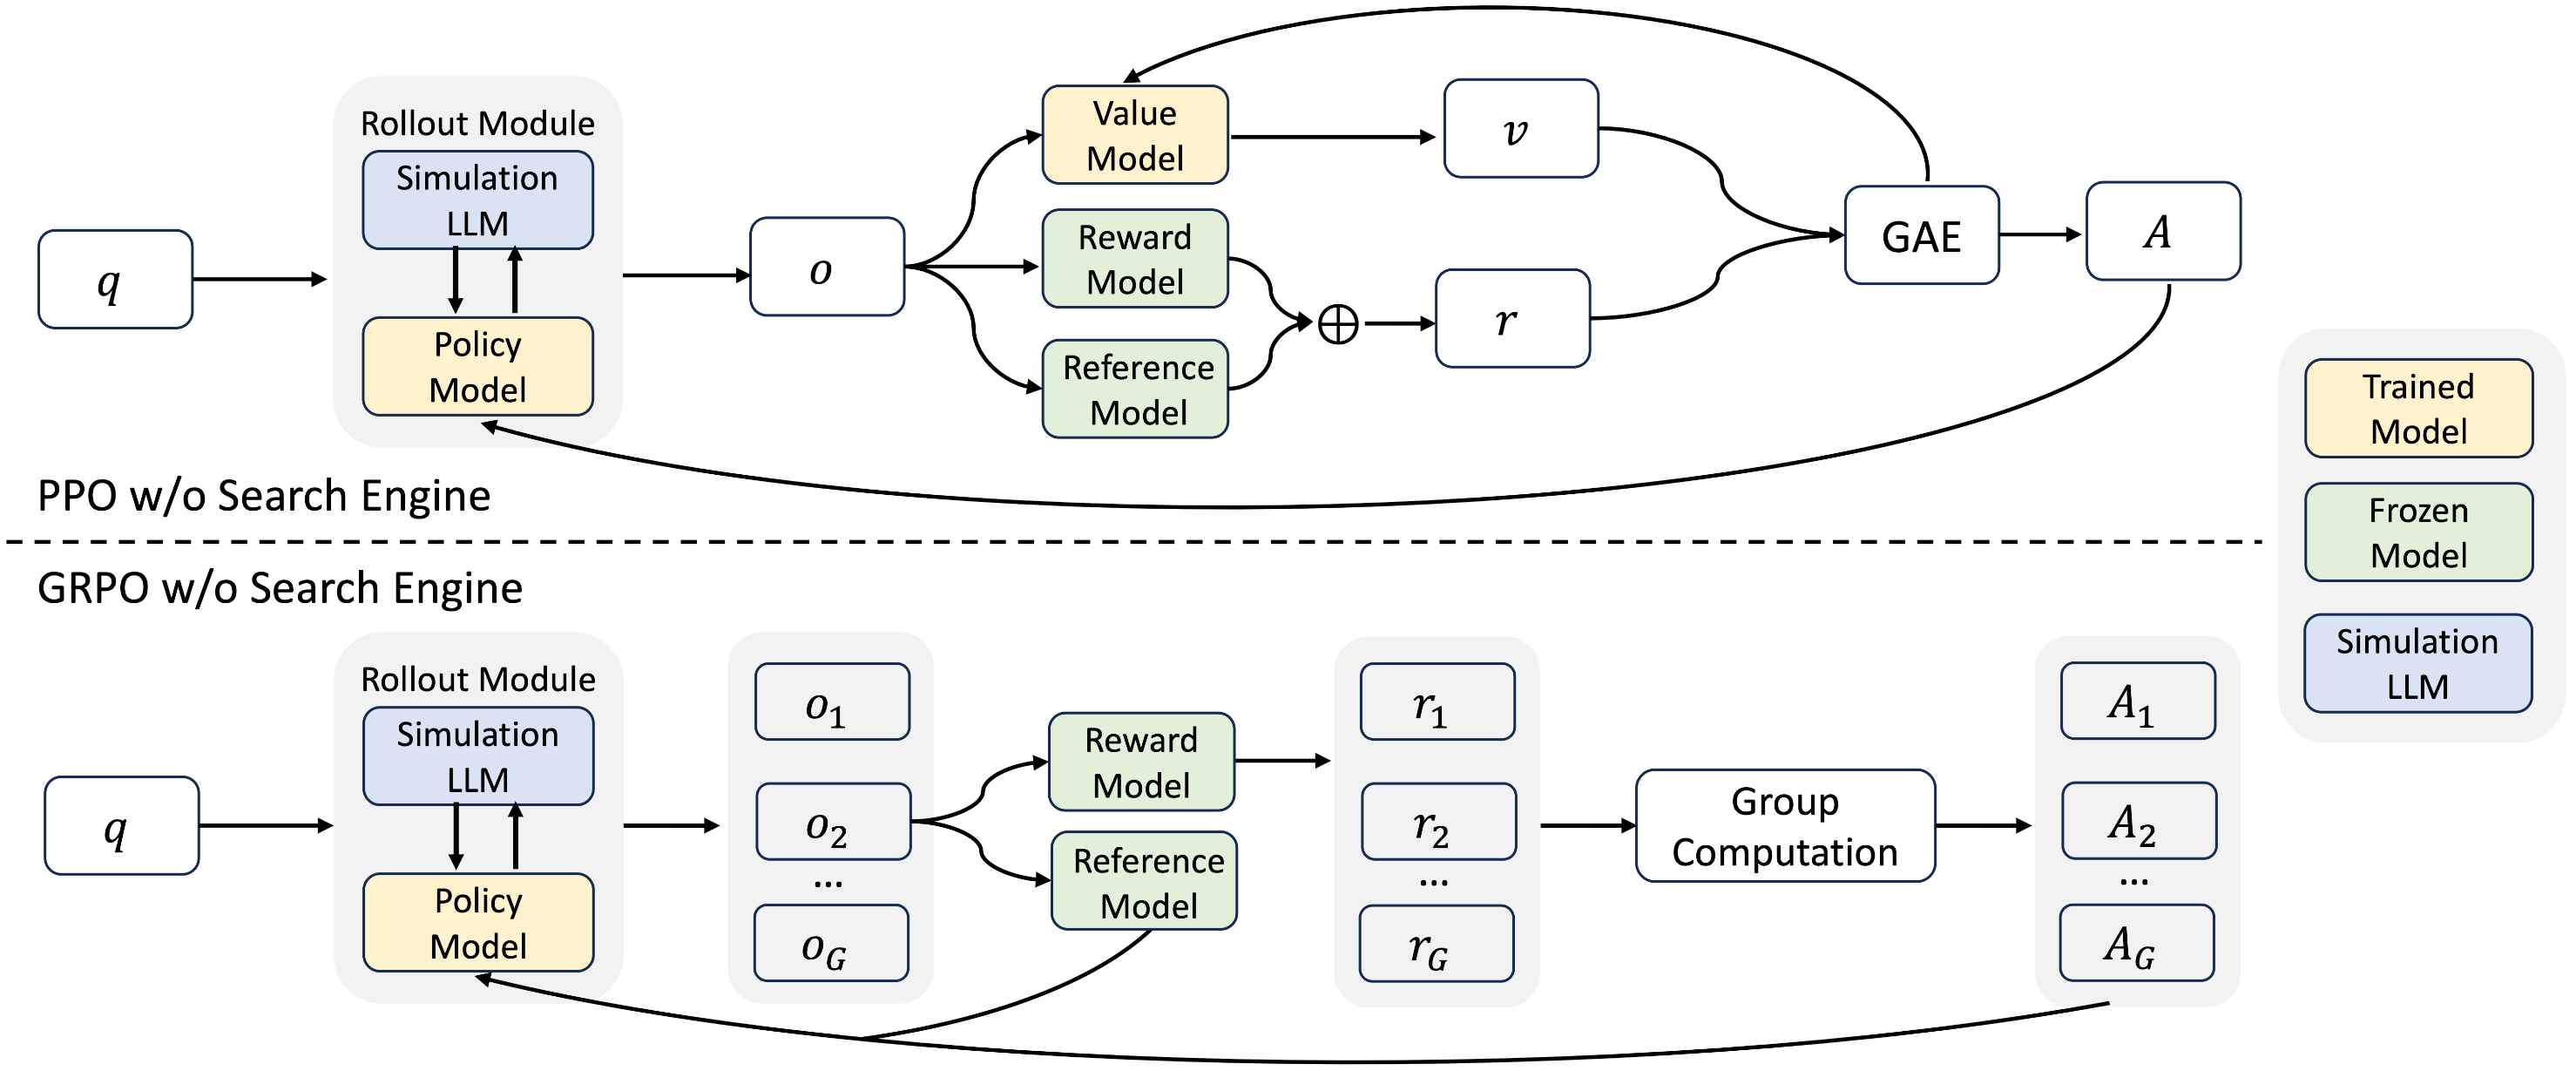
Trains search agents through simulated retrieval interactions and reinforcement learning.
PHYSICAL INTELLIGENCE · WORLD MODELING
Co-author
Jointly models robot actions and future visual states autoregressively, using action attention masking to reduce error accumulation.
Research progressionWorldVLA precedes RynnVLA-002. The original repository now redirects to the successor project, which shares the code entry point.
PHYSICAL INTELLIGENCE · VISION–LANGUAGE–ACTION
Co-author
Uses first-person human manipulation videos for pre-training, with trajectory-aware modeling and ActionVAE to transfer demonstrations to robot control.
Jiayan Guo
I work on post-training for general-purpose agents at Tencent. I focus on how agents organize tasks, use tools, and carry out multi-step workflows.
Previously, I worked on embodied intelligence at Alibaba DAMO Academy. I led the development of ZeroSearch, a training framework for search agents. I was also one of the project leads for RynnBrain, where I was responsible for model pre-training and post-training. My research covers search agents, multimodal learning, and embodied intelligence.
WSDM 2023 Best Paper Honorable Mention; National Scholarship for Doctoral Students; Beijing Outstanding Graduate. View papers ↘
Graph learning and recommender systems.
EARLIER WORK · GRAPH LEARNING & RECOMMENDATION
Graph collaborative filtering with Jacobi polynomials to model signals between users and items.
Embodied foundation models for the physical world.
Acceptance information follows the authors’ arXiv metadata.
The accepted title of RynnVLA-002.
Trains search capabilities in large language models through simulated search interactions.
Applies conditional diffusion models to automated bidding decisions.
Models multi-level user intent for session-based recommendation.
Best Paper Award · Honorable MentionUses Jacobi polynomials to model signals on user-item graphs.
No selected papers for this year. Choose another year or view all papers.
Compiled from public profiles, code repositories, and original papers. Published papers and preprints are labeled separately.
General-purpose agents · Model post-training
Ph.D. in Intelligence Science and Technology
Bachelor’s degree in Computer Science and Technology